About Me
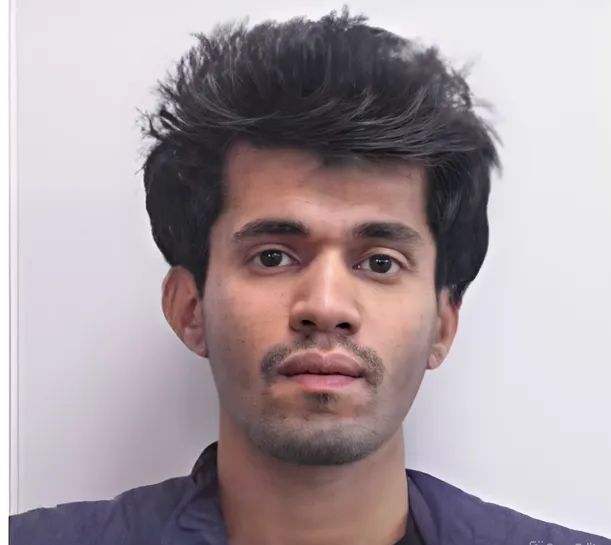
I am currently pursuing a Ph.D. in Mechanical and Aerospace Engineering at Rutgers University, with research interests in dynamics, control, and autonomous robotic systems. My work focuses on developing safety-critical control algorithms for aerial robotic platforms, with an emphasis on bridging theoretical control methods and their practical implementation on real-world systems.
My research involves working with the PX4 open-source flight control software, ROS 2, and autonomous UAV platforms to design, implement, and experimentally validate advanced control algorithms. I am particularly interested in Control Barrier Functions (CBFs), optimization-based control, anti-windup strategies, and other techniques for ensuring the safe operation of autonomous systems.
Prior to my Ph.D., I earned a Master’s degree in Robotics from the NYU Tandon School of Engineering and a Bachelor’s degree from Netaji Subhas Institute of Technology, Delhi University, India. During my master’s program, I gained hands-on experience designing and implementing control algorithms on robotic manipulators, including the UR16e and Franka Emika, while also building a strong foundation in robot localization, navigation, perception, and optimization.
Earlier, I worked with drones based on the PX4 flight stack at Omnipresent Robot Tech, where I contributed to the development of software for autonomous aerial systems and gained experience integrating hardware and software for real-world robotic applications.
Looking ahead, I aim to contribute to the development of safe, reliable, and intelligent autonomous systems by combining advances in dynamics, control theory, optimization, and learning-based methods with practical implementation on robotic platforms. My long-term research interests include autonomous aerial vehicles, aerial manipulation, and multi-agent robotic systems.